


Gripper guide for
High-mix low-volume manufacturing
A working reference on specifying, choosing and integrating grippers for cobots and humanoid robots in high-mix, low-volume production. Written for the people who have to make the decision.
Maintained by the Apicoo Robotics engineering team · Last updated August 2026
Start here
Where should you start?
Pick the option that matches where you are today - each one leads straight to the right chapter.
Chapter 1
Foundation
What the categories mean, and where the boundaries actually fall.
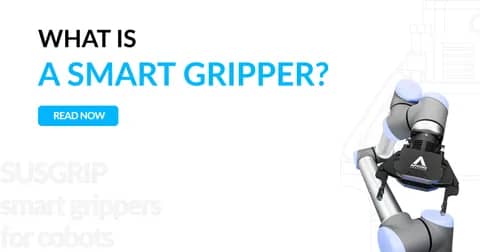
What’s a Smart Gripper?
Have you ever wondered what a smart gripper is and how it can transform automation for high-mix, low-volume (HMLV) manufacturing ? If you're constantly switchin
Updated: October 4, 2026
Exploring Different Types Of Robotic Grippers In Manufacturing
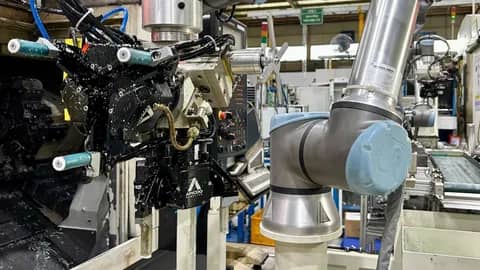
In today’s fast-paced manufacturing landscape, robots are becoming essential for addressing labor shortages, rising costs, and the demand for efficient producti
Updated: October 4, 2026
Chapter 2
How grippers work
The mechanisms behind the specifications, and what each costs to achieve.
Guides for this chapter are coming soon.
Chapter 3
Choosing a gripper
Selection guides organised by the decision you are actually making.
Guides for this chapter are coming soon.
Chapter 4
Humanoid robots
Where humanoid robots are headed, and how the gripper fits in - especially for high-mix, low-volume production.
Guides for this chapter are coming soon.
Chapter 5
Putting grippers to work
Control, integration and getting a cell running. For step-by-step install and wiring detail, see the full SusGrip Technical Guides ↗
Guides for this chapter are coming soon.
Collaboration
Have field experience worth sharing?
We welcome guest contributions from engineers working with grippers, cobots or humanoids.